| Mobility modes | Legged + wheeled (hub-drive wheels with lock) | Switch between walking and rolling in the field |
| Ground contact | Foot pads + drive wheels | Wheels for speed on open ground, legs for stairs and rough terrain |
| Max wheeled speed | ~18 km/h (5.0 m/s) | Flat terrain, wheeled mode |
| Gait configurations | Trot + custom gaits + wheeled rolling | Via motion controllers |
| Weight | ~23 kg | Including battery |
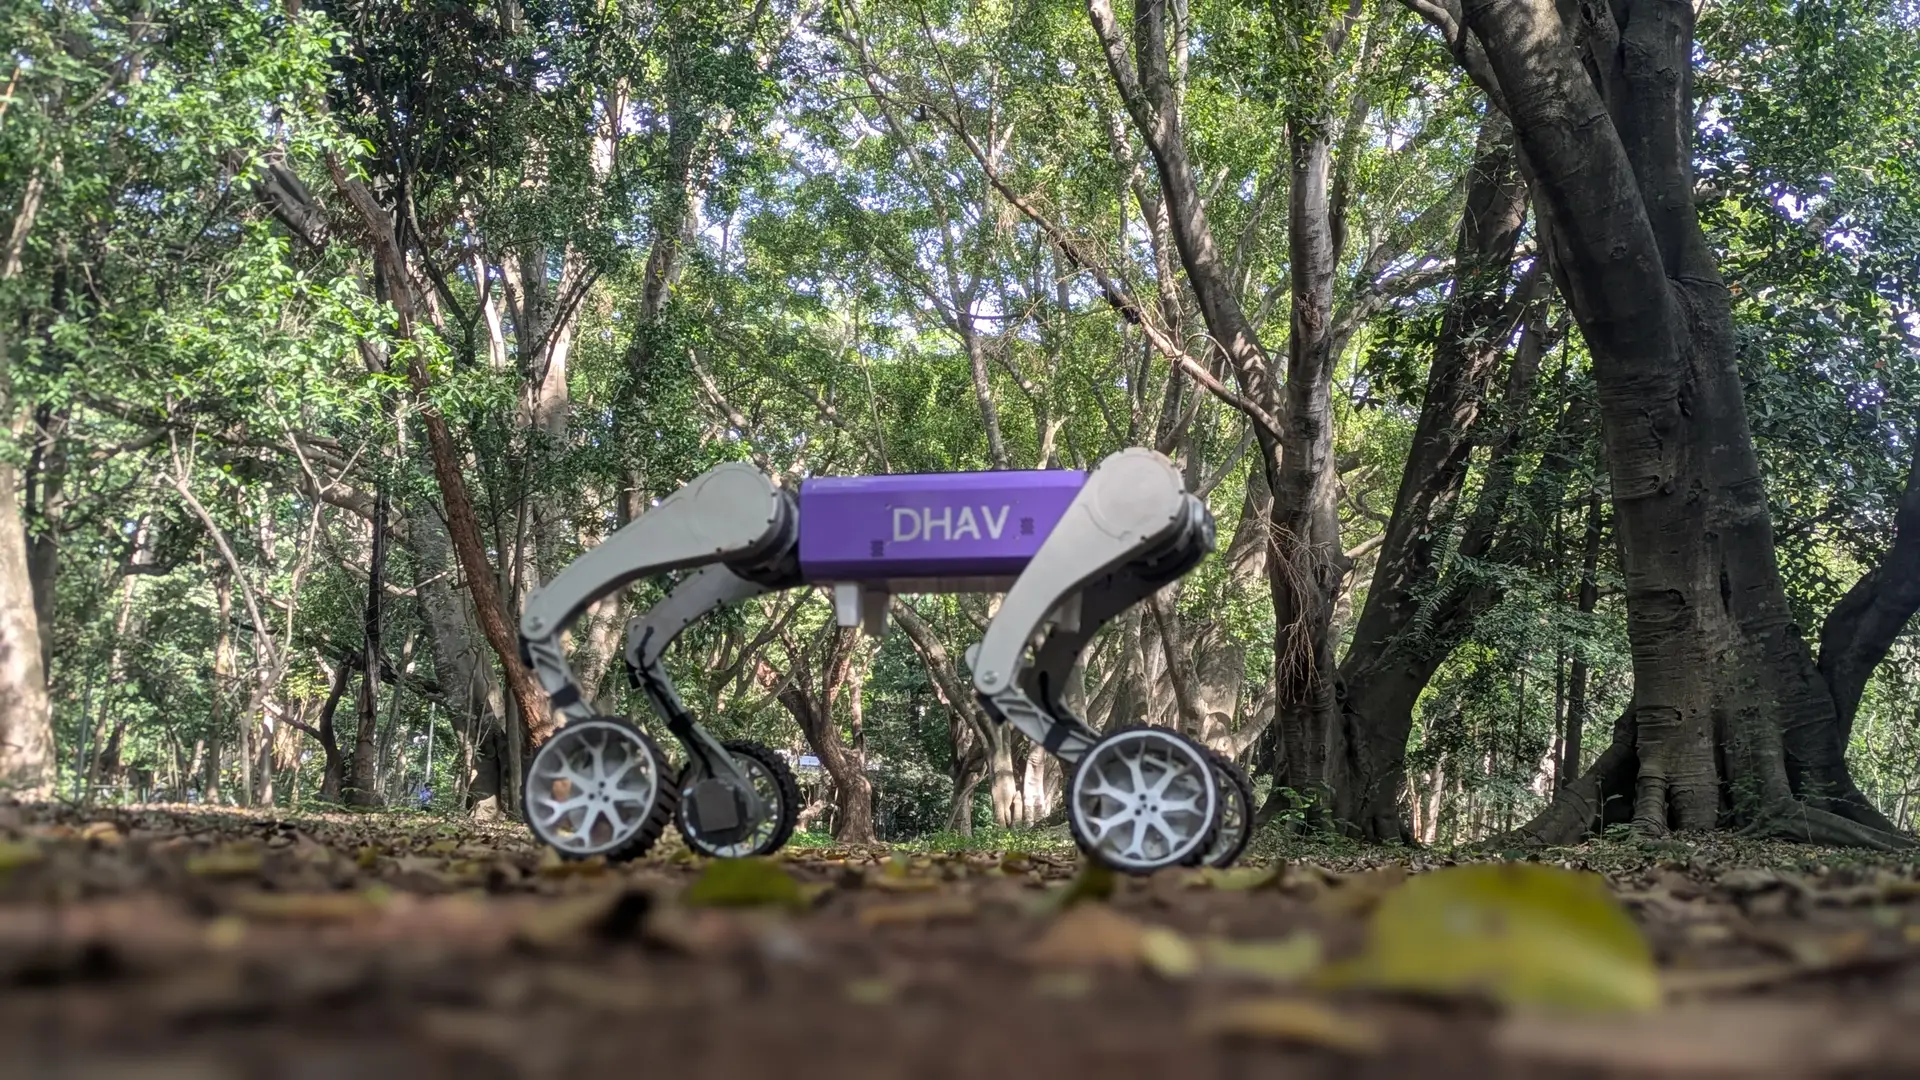
Dhav-Hy / PRE-SALES OPEN
xTerra Robotics / WHEELED-LEGGED PLATFORM
ROLL FAST,WALK ANYWHERE.
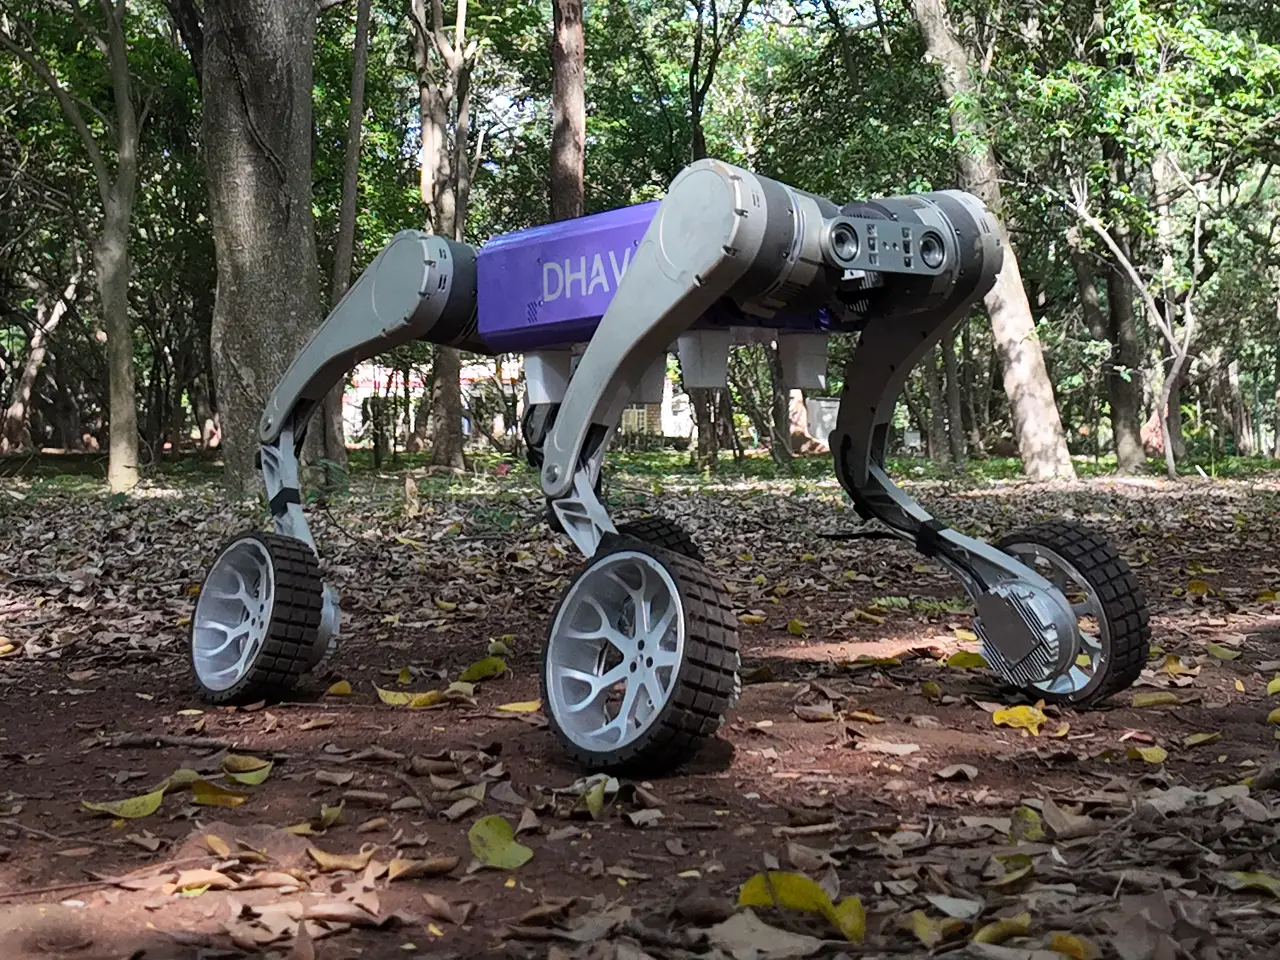
The wheeled-legged variant of DHAV, engineered to roll fast over open ground and walk across the terrain wheels can’t.
01 / THE PURPOSEOPEN GROUND / ROUGH TERRAIN
SPEED WHERE
IT’S OPEN.
LEGS WHERE IT’S NOT.
Dhav-Hy / HYBRID MOBILITY
Dhav-Hy shares the DHAV platform and adds hub-drive wheels, so one robot can cover large areas quickly and still climb stairs and cross rough ground.
SECURITY◆SURVEILLANCE◆CONSTRUCTION◆INDUSTRIAL INSPECTION◆INFRASTRUCTURE◆SECURITY◆SURVEILLANCE◆CONSTRUCTION◆
02 / THE PLATFORMDhav-Hy / WHEELED-LEGGED
ONE PLATFORM / FIVE LAYERSBUILT AS
BUILT AS
A SYSTEM.
Dhav-Hy brings mobility, sensing, edge compute, autonomy and operator control into one field robotics architecture. Pre-sales conversations are open now.
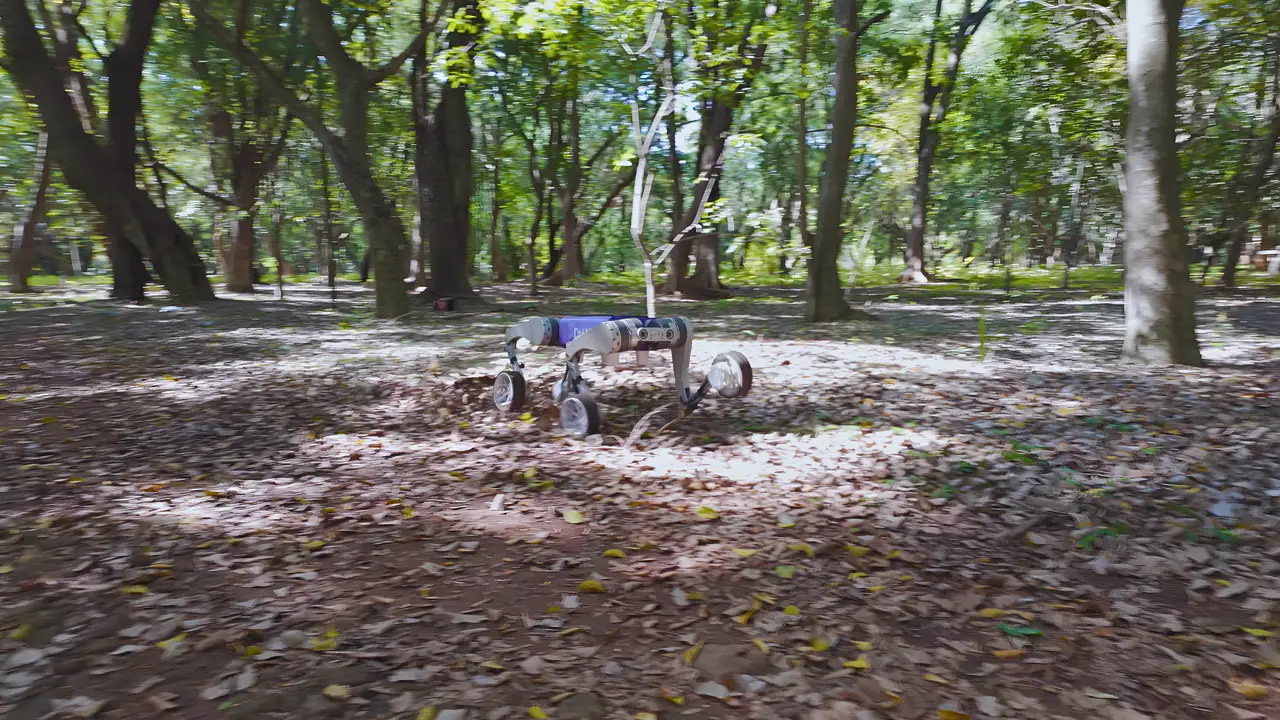 Dhav-Hy / HYBRID PLATFORM
LAYER 01 / MOBILITY
LEGGED + WHEELED
Hub-drive wheels for speed on open ground, and 12 quasi-direct-drive leg actuators for stairs and rough terrain. Switch between rolling and walking in the field.
- ~18 KM/H WHEELED SPEED
- 30 CM STEP HEIGHT
- ~45° CLIMB / DESCENT
03 / THE MISSIONSONE PLATFORM / MANY ENVIRONMENTS
MISSION
DEFINES THE SYSTEM.
SELECT / EXPLORE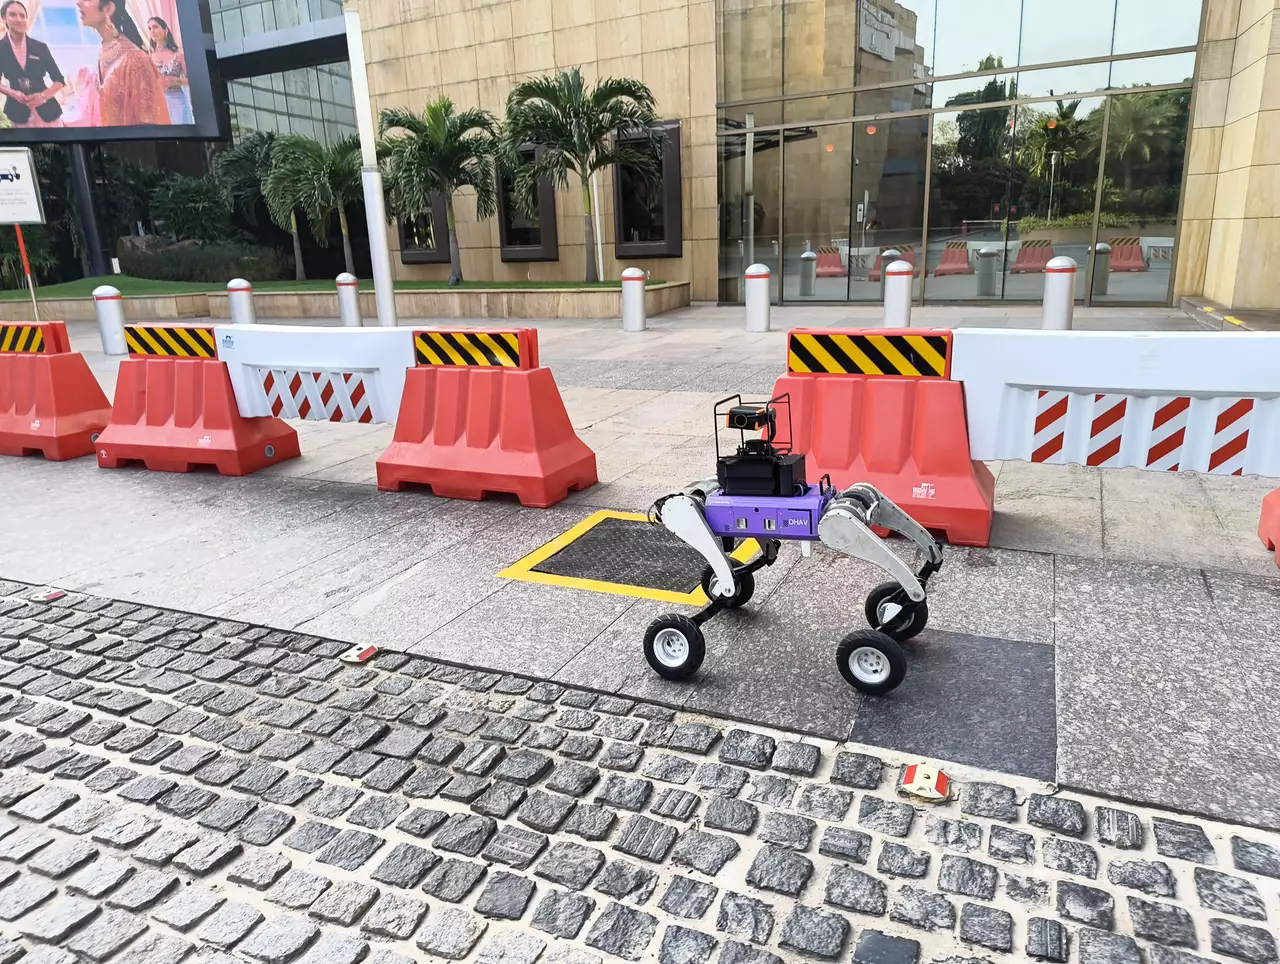
MISSION / 01SECURITY & SURVEILLANCEDhav-Hy / PATROL
04 / IN THE FIELDDhav-Hy / FIELD FOOTAGE
Dhav-Hy / IN ACTIONSEE IT
SEE IT
IN MOTION.
Watch Dhav-Hy take on rough terrain, slopes and stairs.
05 / THE INTELLIGENCEAUTONOMY / ROS2
Dhav-Hy / AUTONOMY STACKINTELLIGENCE
INTELLIGENCE
AT THE EDGE.
Built around on-board perception, navigation and a ROS2 + Python / C++ SDK, so operators can focus on intent while the platform handles the complexity of movement and sensing.
INPUT / 01HUMAN
INTENTMISSION OBJECTIVE
INTENTMISSION OBJECTIVE
01PERCEPTION↓
02UNDERSTANDING↓
03PLANNING↓
04ACTION→
OUTPUT / 04FIELD
ACTIONHUMAN-DIRECTED
ACTIONHUMAN-DIRECTED
CONCEPTUAL ARCHITECTURE / CAPABILITIES SUBJECT TO ENGINEERING DEVELOPMENT
06 / PERCEPTION INTERFACE
PERCEPTION / CONCEPTSEE THE
SEE THE
MISSION.
A conceptual visualization of how LiDAR, depth sensing, path planning and mission context could come together in an operator-directed system.
Dhav-Hy / PERCEPTIONCAM 01 / WIDEDEMO ENVIRONMENT
PERSON / 12.4m
OBSTACLE / 8.1m
STRUCTURE
WP-04
SAFE PATH / COMPUTINGLIDAR / 360°WAYPOINT / 04
CONCEPTUAL INTERFACE / DEVELOPMENT VISUAL
07 / OPERATOR EXPERIENCEINTERFACE / CONCEPT
HUMAN / MACHINEDIRECT THE
DIRECT THE
MISSION.
A conceptual command environment built around clarity, mission context and human intent. All values shown are placeholders.
LINK / CONNECTED
UNIT / Dhav-Hy-001
OVERVIEW / ACTIVEDEMO / CONCEPT
18°32'42.1"N
73°51'24.4"E
73°51'24.4"E
CAM / 01OVERVIEW FEED
CONCEPTUAL Dhav-Hy OPERATOR INTERFACE / PLACEHOLDER DATA
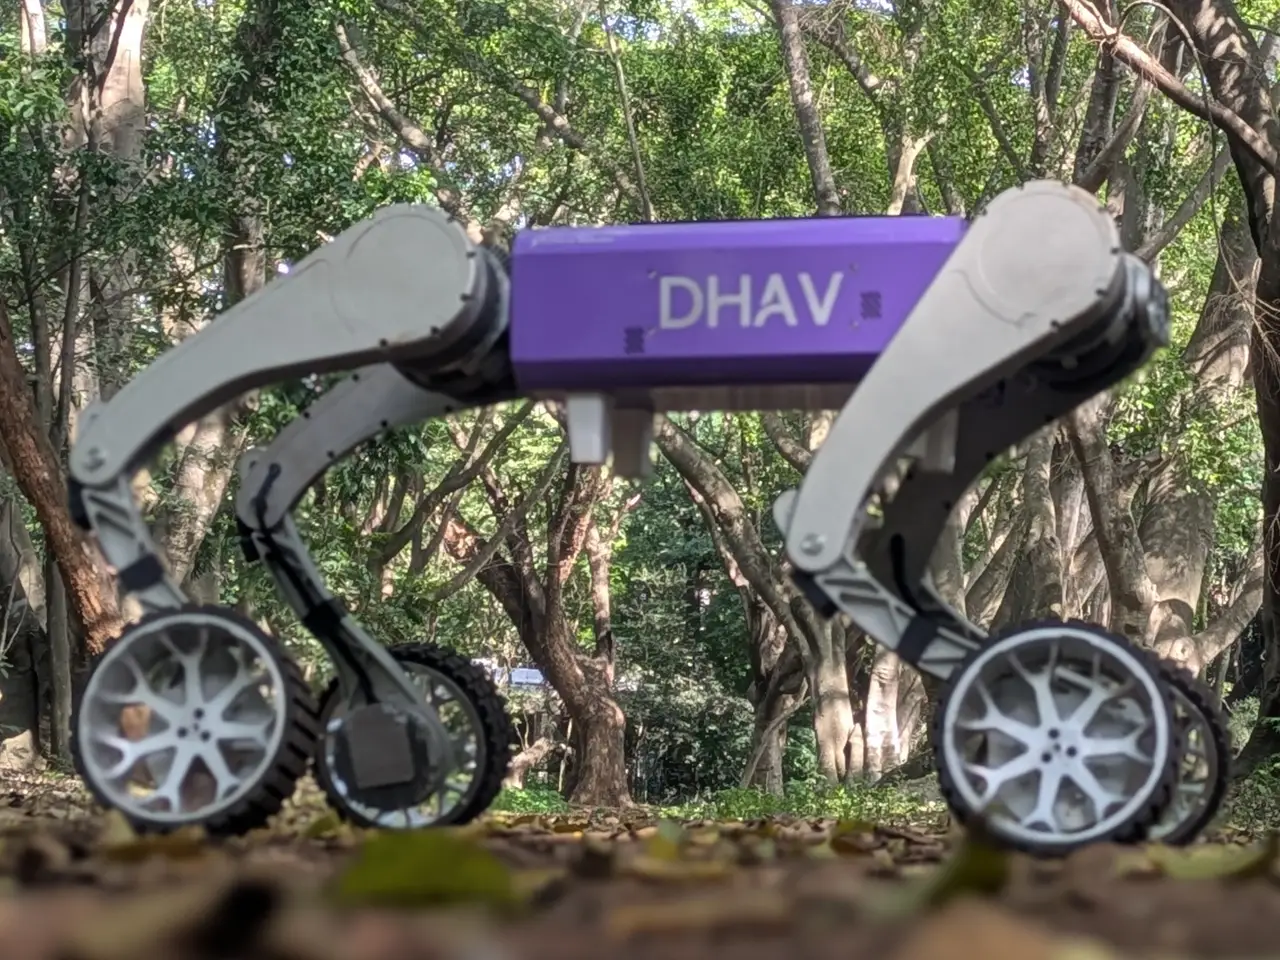
08 / TECHNICAL SPECIFICATIONSDhav-Hy / INDICATIVE
ENGINEERED FOR
THE REAL WORLD.
Technical specifications for the Dhav-Hy platform. Figures are indicative and confirmed at order.
| Build material | High-strength aluminum alloy | Body + legs structural framework |
| Actuators (DoF) | 12 quasi-direct-drive leg actuators | 3 per leg: 2× hip, 1× knee, plus wheel hub drives |
| Max leg joint torque | Hip/thigh 40 Nm · Knee 80 Nm | Field-oriented control (FOC), joint level |
| Joint range of motion | Hip abd/add −55° to 55° · hip flex/ext −200° to 90° · knee flex/ext −156° to −50° | Positive rotation anti-clockwise |
| Climb / descent angle | ~45° | Legged mode, without payload |
| Stair-climbing capability | Up to 30 cm step height | Legged mode, standard stair geometry |
| Battery type & pack | Lithium-ion 7S4P | ~25.2 VDC nominal (29.4 V max), 20 Ah / ~504 Wh |
| Battery management | Smart BMS (7S–24S, 100 A) | 80 A peak charge/discharge |
| Swappable battery | Yes | Quick-swap design, external charger |
| Charging time | 90 minutes (0–100%) | Fast charging supported |
| Minimum endurance | ≥120 minutes | Flat terrain, no payload, 25–30 °C |
| Power management | Auto power-saver mode | Sleep mode while idle |
| 3D LiDAR | 360° FOV, high-precision | Range 40 m @10% / 70 m @80% reflectivity · precision ≤3 cm |
| Stereo depth + RGB camera | 0.26 – 3 m range | Depth FOV 90°×65° · up to 1280×800 @30fps |
| IMU | 6-axis, high-precision | Stabilization and navigation |
| Joint encoders | Magnetic, on-axis | ≥14-bit resolution per joint |
| On-board navigation computer | NVIDIA Jetson AI compute module | 1024 CUDA + 32 Tensor cores · 8 GB LPDDR5 |
| On-board locomotion computer | BCM2712 quad-core Cortex-A76 @2.4GHz | 8 GB LPDDR4-4267 · GbE PHY · dual USB 3.0 |
| Joint-level control | Field-oriented control (FOC) | Real-time motor control loops |
| ROS support | ROS2 | Fully integrated framework |
| Software SDK | Python & C++ APIs | For secondary development and control |
| Simulation models | URDF available | Geometric + dynamic models for sim-to-real |
| Robot connectivity | Wi-Fi & Gigabit Ethernet | High-bandwidth wireless and wired comms |
| External payload interfaces | 2× Ethernet, 1× USB, power outlet (12V & 24V) | Dedicated expansion power and data ports |
| Remote tele-operation | RF Joystick + Web Long-Range Teleop | Dual control modality |
| Emergency safety | Physical kill switch | Hardware emergency power cutoff |
| Operating temperature | 0°C to 50°C | Industrial operating range |
| Cooling system | Active torso fan cooling | Thermal management under load |
09 / CONTACTDhav-Hy / PRE-SALES
PRE-SALES / NOW OPENBRING US
BRING US
THE MISSION.
Ready to bring Dhav-Hy into your operations? Say hi to join the pre-sales conversation.
REQUEST PRE-SALES ACCESS