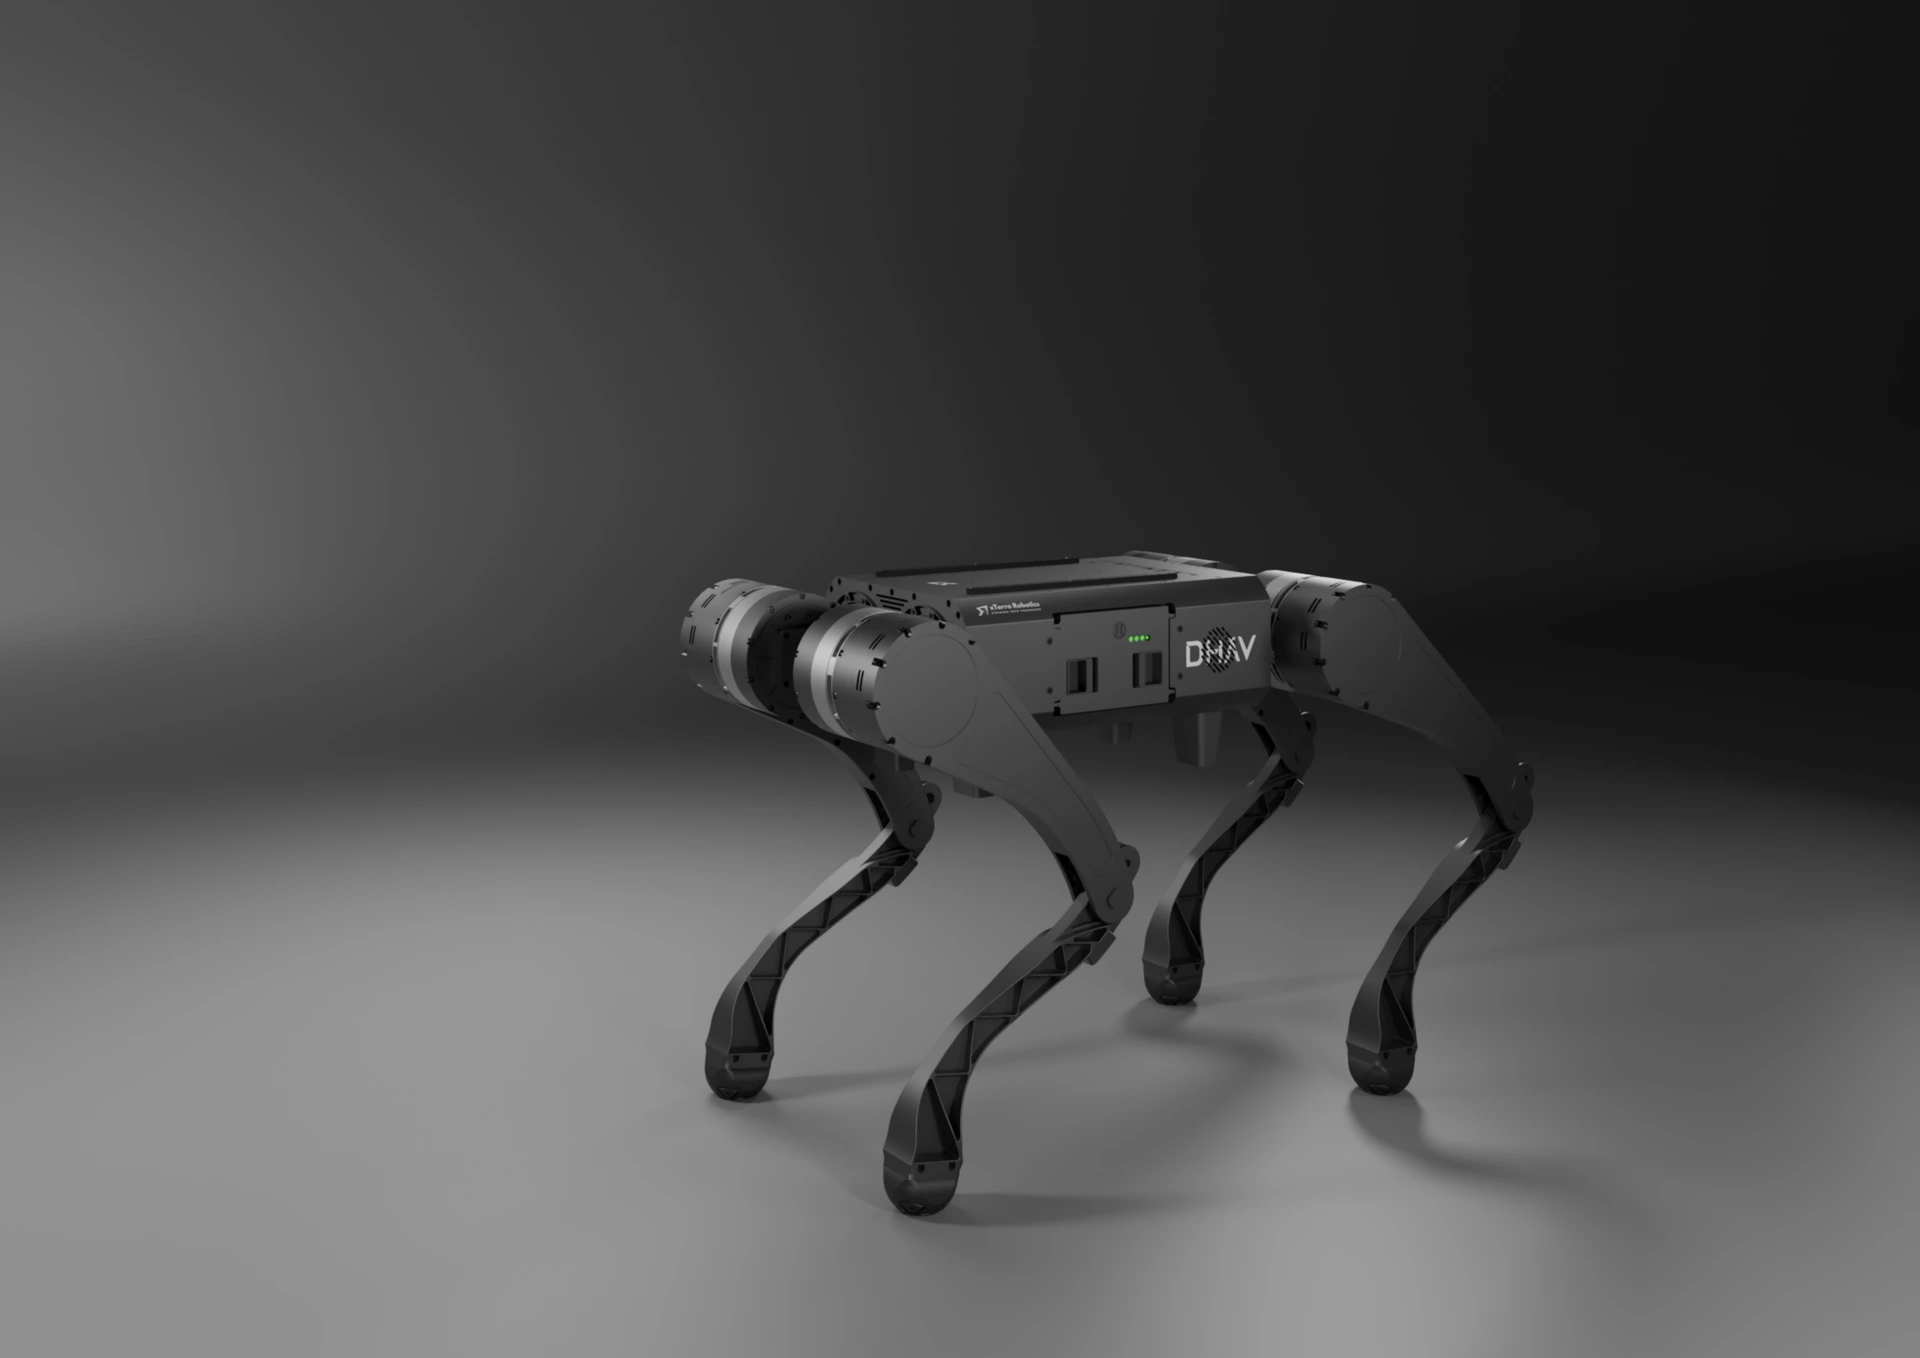
PRE-SALES OPEN
DHAV
India’s next-gen autonomous quadruped, engineered to move, perceive and operate across complex terrain
Platform
One launch platform, built as four system layers. Pre-sales conversations are open now.
Mobility
~12 km/h
Perception
360° 3D LiDAR + stereo depth
Autonomy
ROS2 · Python / C++ SDK
Operator
RF Joystick + Web Long-Range Teleop
Technical Specifications
Full technical specifications for the DHAV platform.
| Dimensions (L × W × H) | 75 × 30.5 × 44 cm | Standing configuration |
| Sleep dimensions (L × W × H) | 75 × 30.5 × 17 cm | Crouched / rest configuration |
| Operating height range | 25 – 48 cm | Ground to top panel |
| Maximum weight | 19.5 kg | Including battery |
| Build material | High-strength aluminum alloy | Body + legs structural framework |
| Payload mounting area | 18 × 30 cm | Mounting rails on top plate |
| Actuators (DoF) | 12 quasi-direct-drive actuators | 3 per leg: 2× hip, 1× knee |
| Max joint torque | Hip/thigh 40 Nm · Knee 80 Nm | Field-oriented control (FOC), joint level |
| Joint range of motion | Hip abd/add −55° to 55° · hip flex/ext −200° to 90° · knee flex/ext −156° to −50° | Positive rotation anti-clockwise |
See DHAV in Action
Watch DHAV move across rock, sand and loose terrain
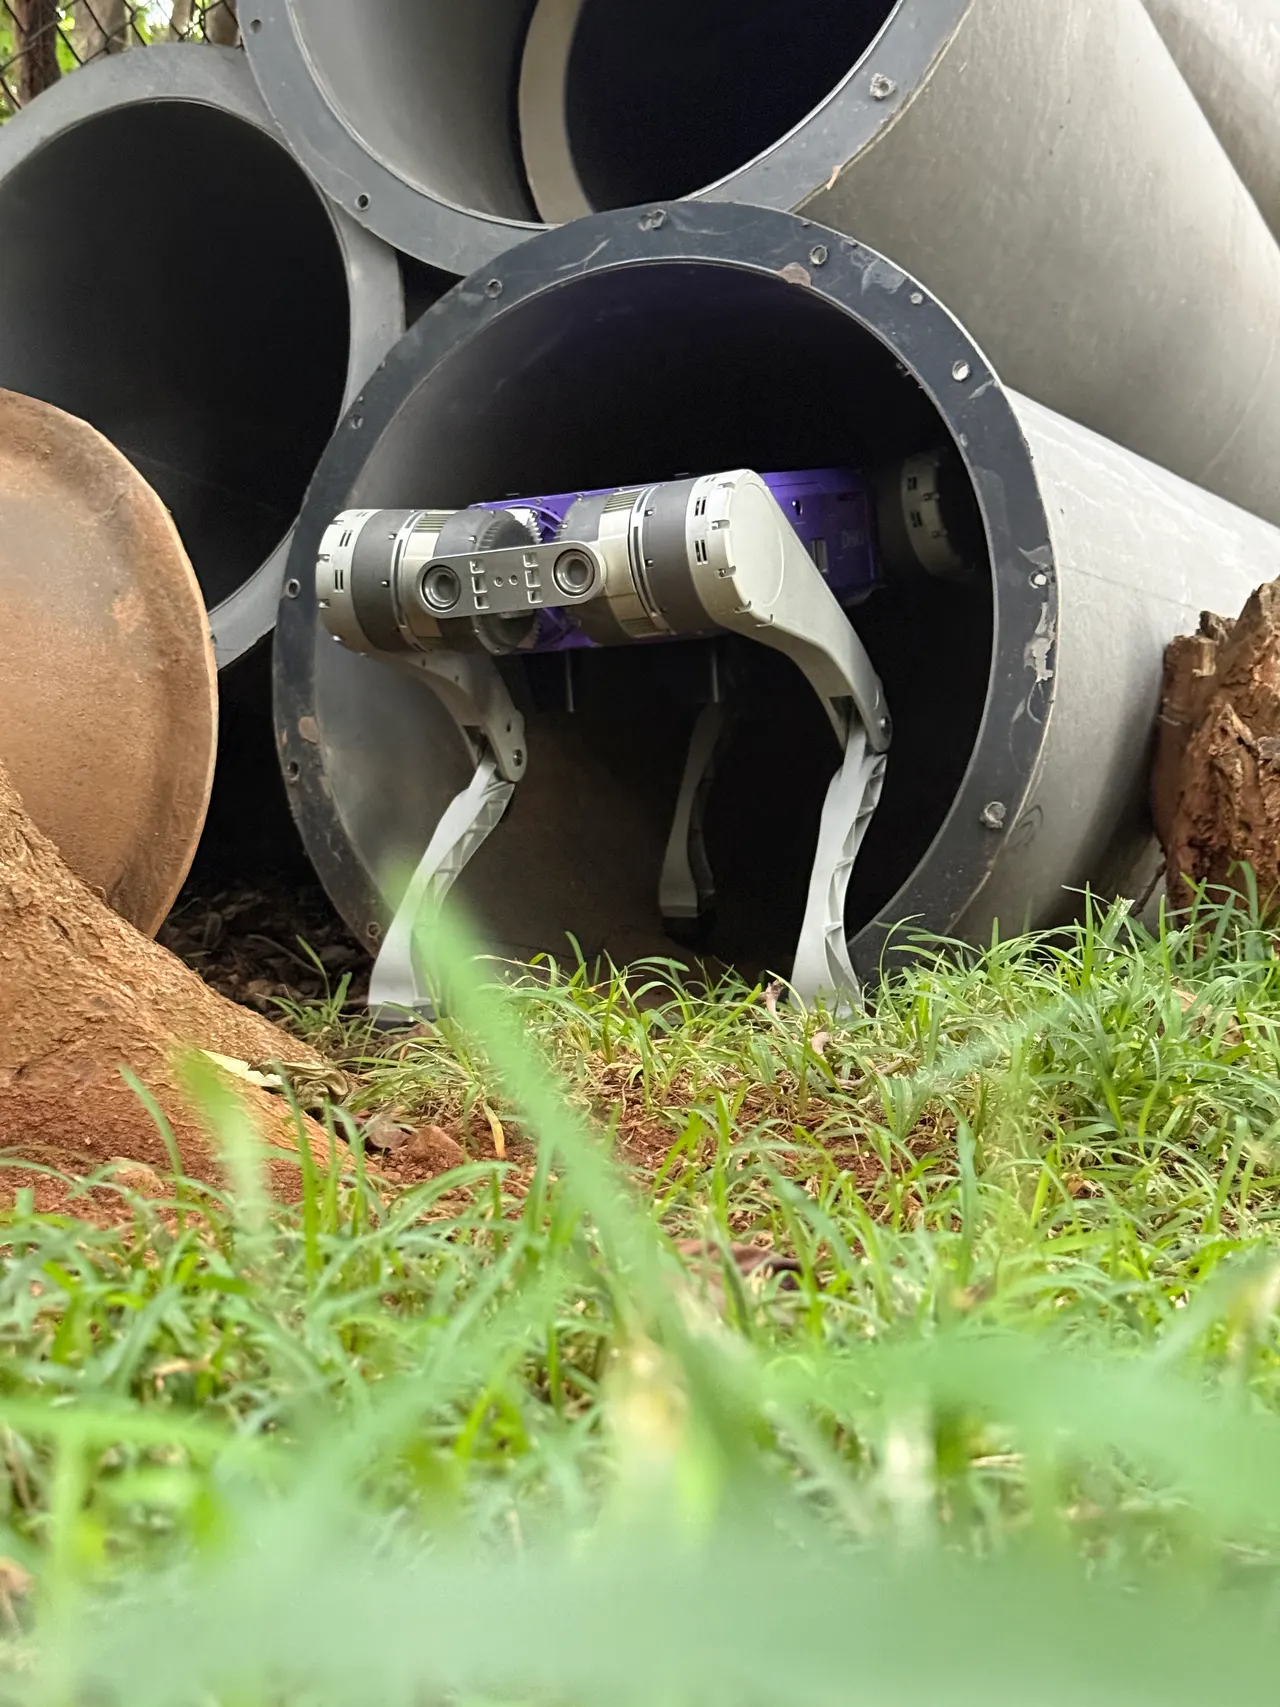
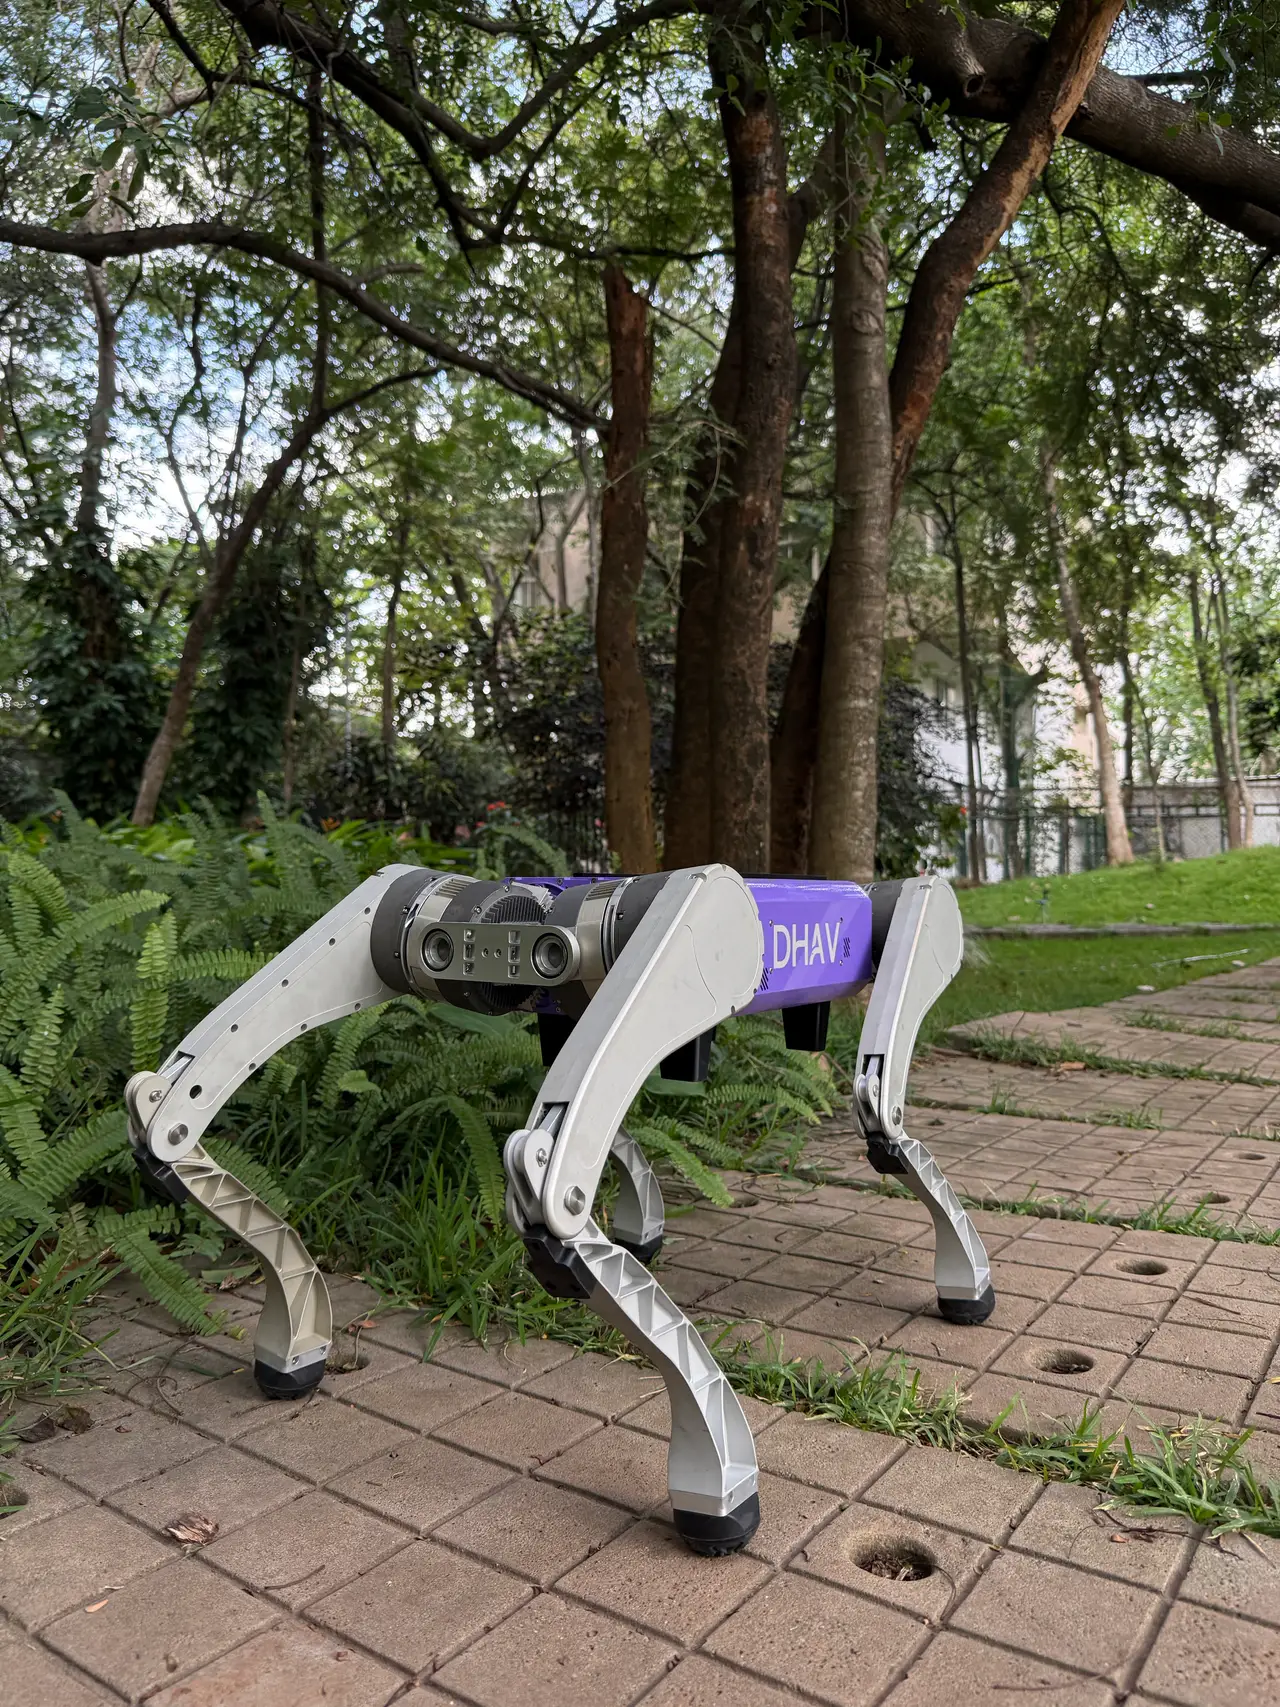
One Platform, Many Environments
The mission defines the system. Select an application to see what DHAV is being engineered for.
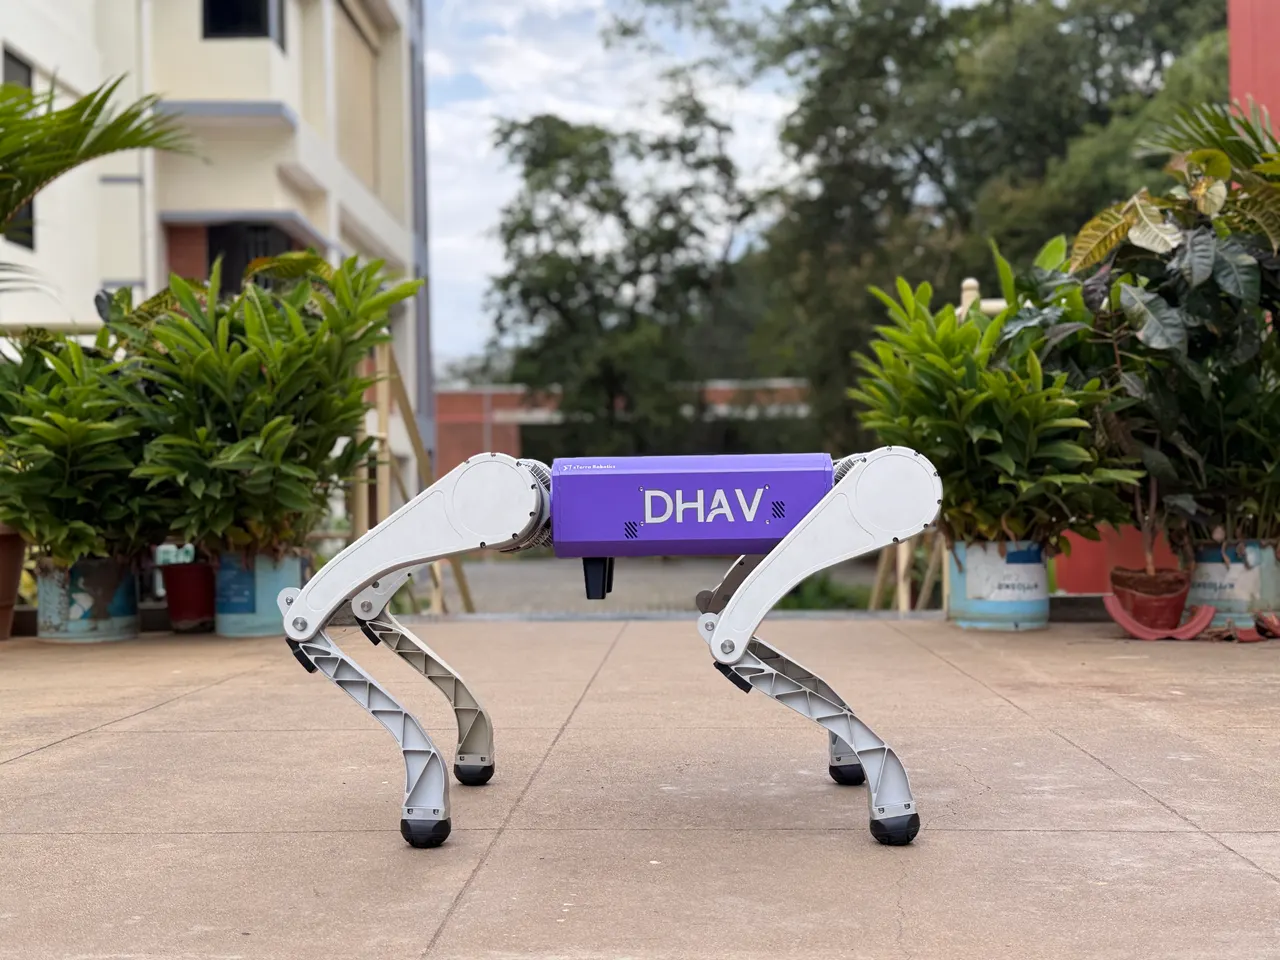
Security & SurveillanceDHAV
Ready to bring DHAV into your operations?
Say hi to join the pre-sales conversation.